$11.99
$14.99
50% OFF! Hot items selling fast—Grab them before they're gone!

 Unconditional Satisfaction GuaranteeNo Shipping Fees Above 302 Months to Decide. Returns Simplified.
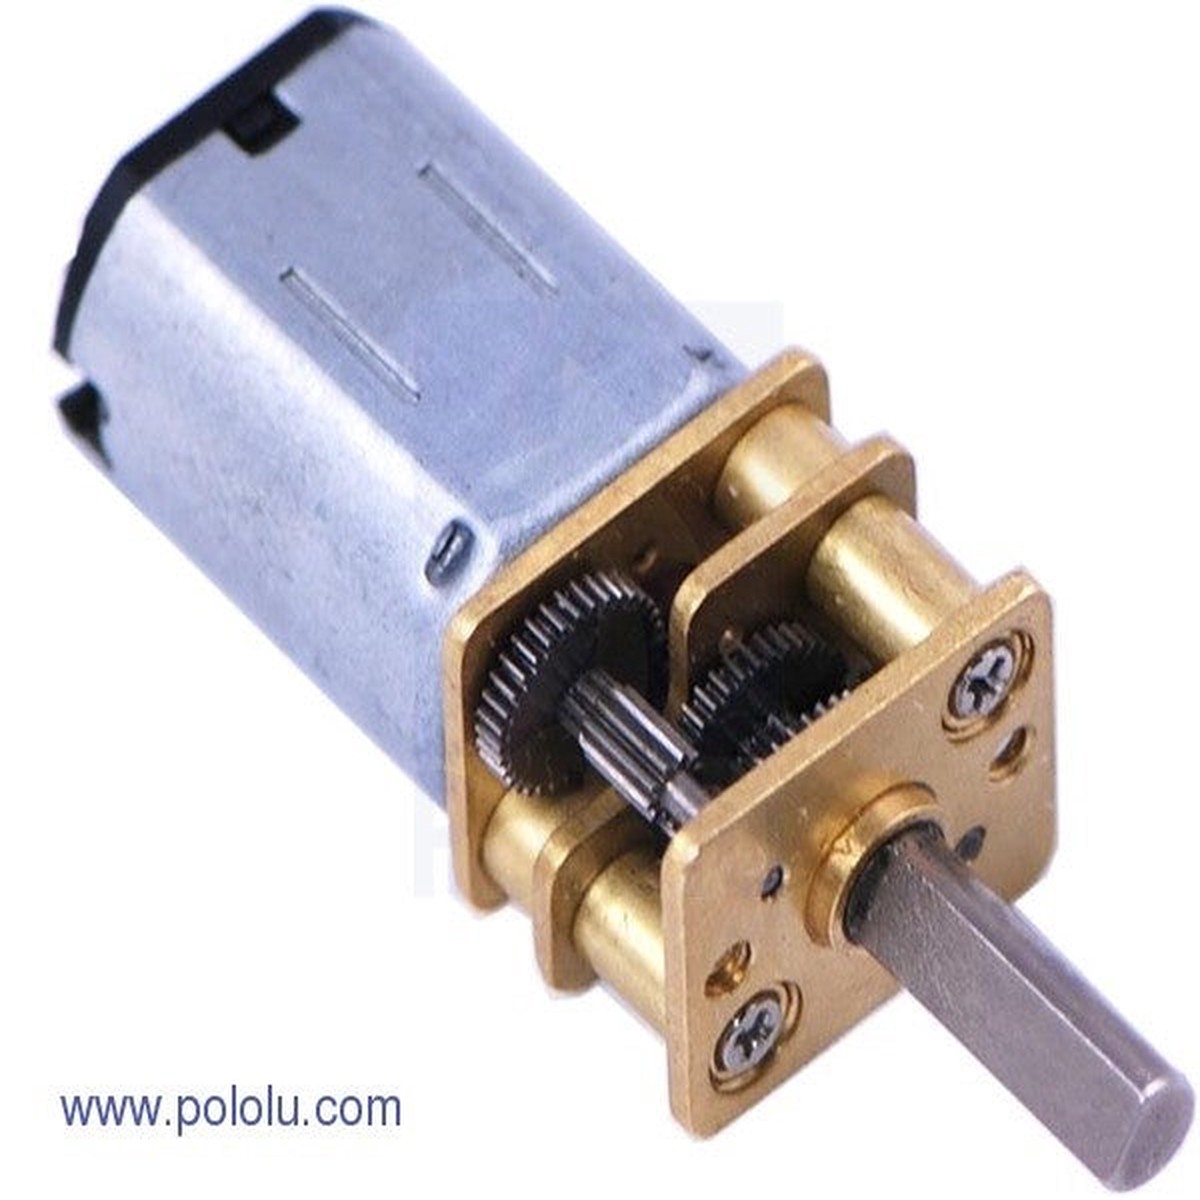
The SteadyWin GIM3505-8 is a high-efficiency planetary gear stepper motor engineered for robotics, automation, and embedded motion control. With a 24V input, 29W output, and an integrated 8:1 reduction gearbox, it delivers stable torque and precise positioning in a compact 43 mm form factor .
Optional driver modules and 14-bit magnetic encoders enable closed-loop CAN bus control, making it ideal for industrial-grade applications such as collaborative robots, exoskeletons, and mobile platforms.
Whether you’re building a smart actuator or a multi-axis robotic joint, the GIM3505-8 offers the reliability and responsiveness you needwithout compromising on size or efficiency .
Compact & Mighty Just 4330mm and weighing only 97g, this motor is tailor-made for micro-robotics, wearable exoskeletons, and space-constrained automation systems.
High Torque Output Delivers a rated torque of 0.65Nm and stall torque up to 1.27Nm, ensuring stable and responsive performance even under demanding loads.
Integrated Driver Equipped with a built-in GDS34 driver board, supporting CAN bus communication for smooth, real-time control in industrial and robotic applications.
Precision Encoder Features an onboard 14-bit magnetic encoder, with options for external encoder integration and a customizable brakeideal for closed-loop systems.
Built for Harsh Conditions Rated IP54 for dust and splash resistance, and operates reliably across a wide temperature range from 20C to +80Cready for field deployment.
| Feature | Unit | Value |
|---|---|---|
| Model | GIM3505-8 | |
| Winding method | / Y (listed) | |
| Winding method (selected) | Y | |
| Driver board model | GDZ34 | |
| Rated voltage | V | 24 |
| Voltage range | V | 1240 |
| Rated power | W | 37 |
| Rated torque | Nm | 0.67 |
| Peak torque (Stall torque) | Nm | 1.79 |
| Rated speed after reduce | RPM | 230 |
| Max speed after reduce | RPM | 400 |
| Rated current | A | 1.53 |
| Peak current (Stall current) | A | 3.99 |
| Phase-to-phase resistance | 5.47 | |
| Phase-to-phase inductance | mH | 0.48 |
| Speed constant | rpm/V | 16.67 |
| Torque constant | Nm/A | 0.44 |
| Number of pole pairs | Pairs | 11 |
| Gear rate | 8:1 | |
| Gear type | Planetary | |
| Reducer gear material | ALU | |
| Reducer gear backlash | arcmin | 15 |
| Motor weight without driver | g | 84 |
| Motor weight with driver | g | 97 |
| Size without driver | mm | 43 23.6 |
| Size with driver | mm | 43 30 |
| Max axial load | N | 75 |
| Max radial load | N | 300 |
| Noise | dB | <60 |
| Communication | CAN & RS-485 | |
| Second encoder (the second encoder on the output shaft) | NO | |
| Protection grade (Motor Protection Grade) | IP54 | |
| Working temperature | C | -20 to +80 |
| Resolution of the encoder on the driver | Bit | 14 bit |
| Can support separate encoder or not | YES | |
| Can support custom brakes | YES |
Robotic joint modules
Exoskeleton actuators
Gimbal stabilizers
UAV propulsion systems
Industrial automation
| Feature | V1.0 | V1.1 |
|---|---|---|
| Encoder Type | AS5047P (external magnetic encoder) | MT6816 / MA7XX (integrated encoder) |
| Driver Compatibility | Not compatible with GDS/GDZ drivers | Compatible with GDS34 / GDZ34 |
| Communication Protocol | SPI only | CAN / RS-485 |
| Integration Level | Encoder only, no onboard driver | Integrated driver + encoder |
| Second Encoder Support | Not supported | Supported (via GDZ driver with MA7XX input) |
| Application Focus | Custom control systems, MCU integration | Plug-and-play motion control, industrial use |